CAPTURE SYSTEMS
Make human skill trainable.
A unified family of wearable, handheld and teleoperation systems for collecting multimodal robot-learning data in real tasks.
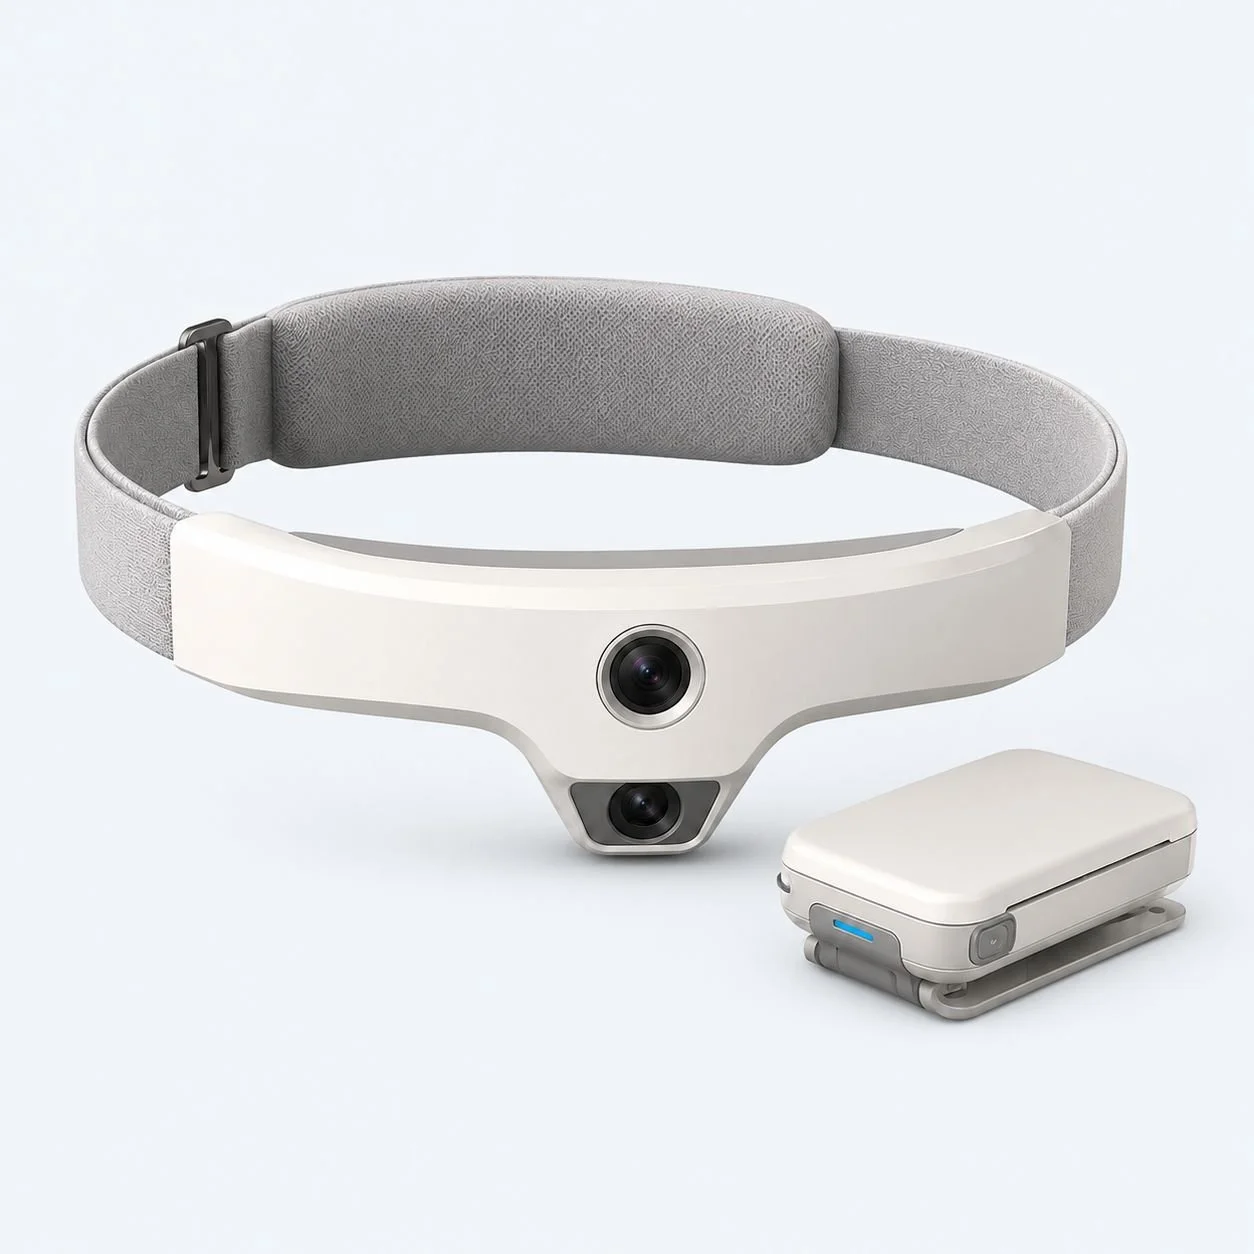
EGO LITE
Lightweight first-person capture
Low-burden capture for scaled data collection in hotels, offices, retail, laboratories and industrial tasks.
- 2 RGB global-shutter cameras
- 6-axis IMU
- Hardware synchronization
- Up to 8 hours runtime
- Waist compute and storage hub
- REF and LeRobot export
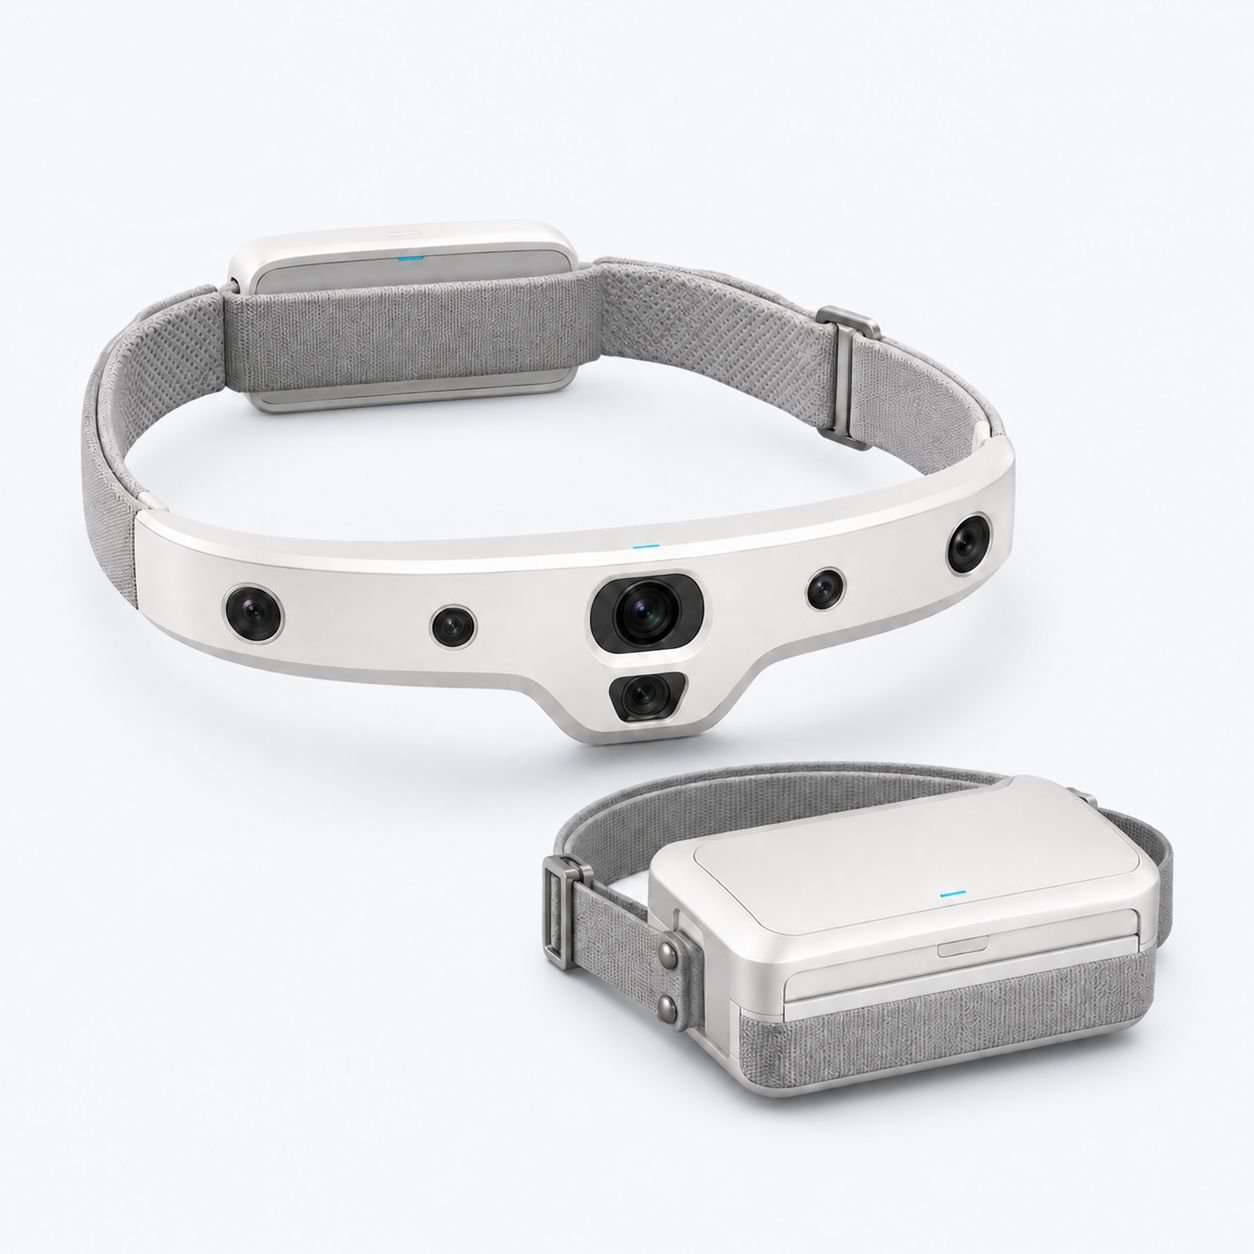
EGO PRO
Six-camera spatial capture
Global shutter, hardware synchronization, VIO and multi-view coverage for complex indoor manipulation and high-quality training datasets.
- 4 RGB + 2 monochrome global-shutter cameras
- Stereo VIO
- Dual IMU
- Hot-swap battery architecture
- 2 TB NVMe configuration
- OEM and project customization
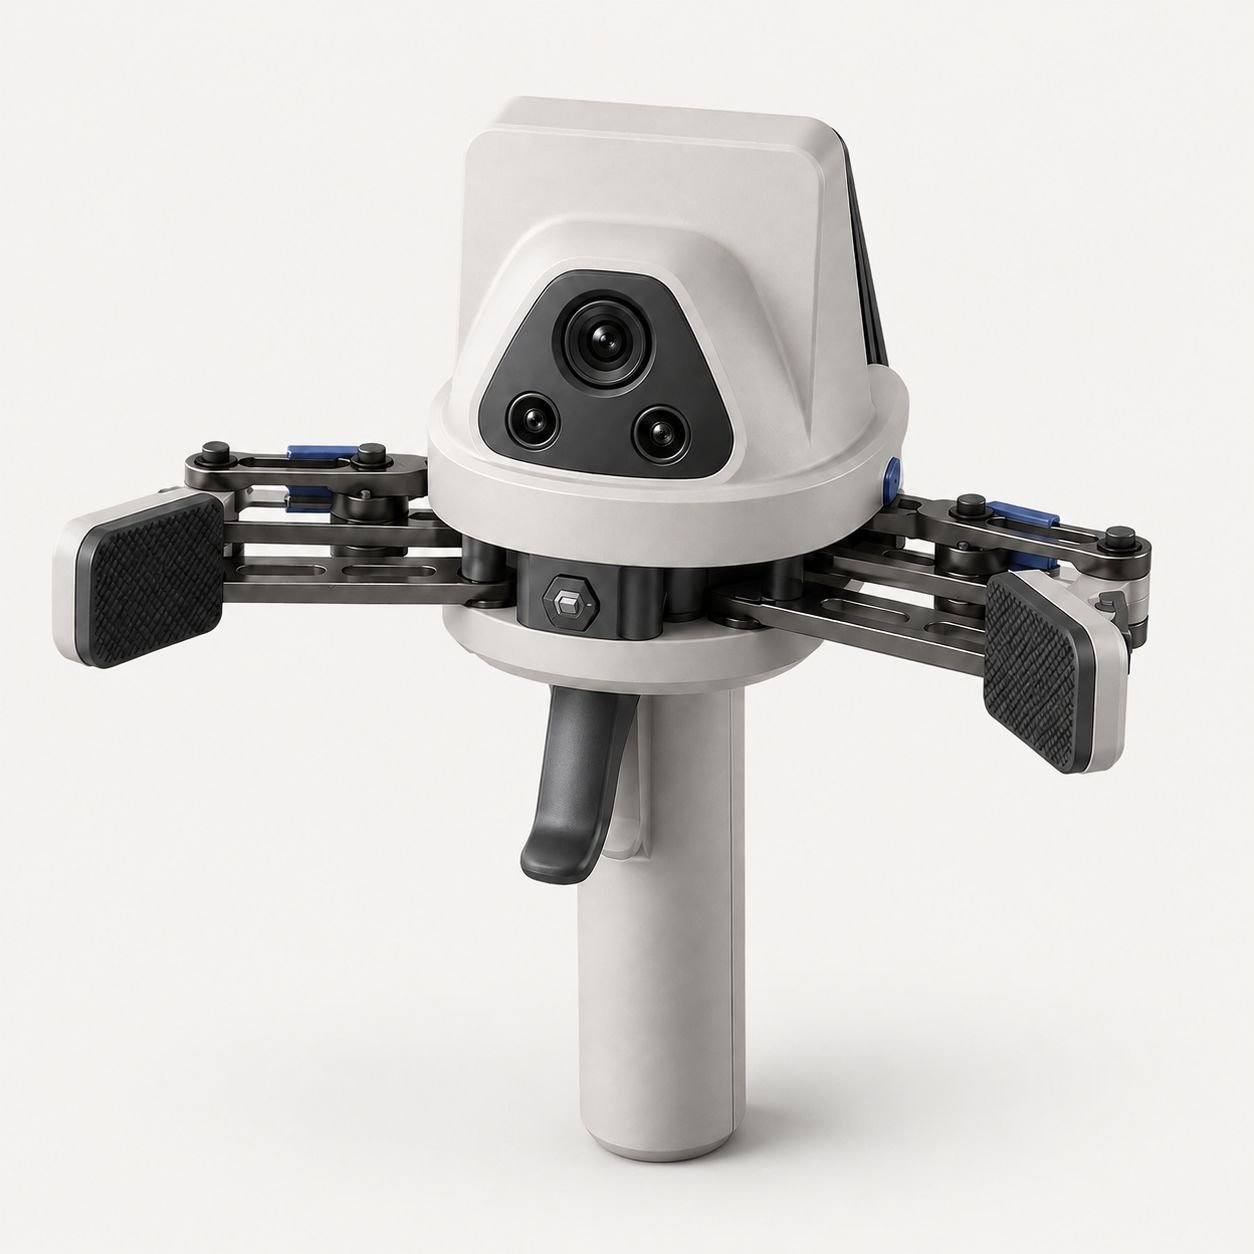
UMI PRO
Universal Manipulation Interface
Synchronize vision, pose and gripper action at the end effector. UMI Pro connects human demonstrations with robot-ready action data.
- RGB and stereo vision
- 6DoF VIO
- Gripper opening and action state
- Hardware synchronization
- On-device storage and wireless transfer
MASTER TELEOPERATION DEVICE
IN DEVELOPMENT
An isomorphic master device inspired by surgical teleoperation consoles, designed for precise bimanual demonstrations, long-duration operation and synchronized command capture.
HAPTIC GLOVES
IN DEVELOPMENT
Hand motion and interaction capture with tactile extensions for dexterous manipulation, contact-rich tasks and future force-feedback workflows.
Development configurations and specifications are finalized for each project and acceptance plan.