Turn Human Experience Into Robot Action
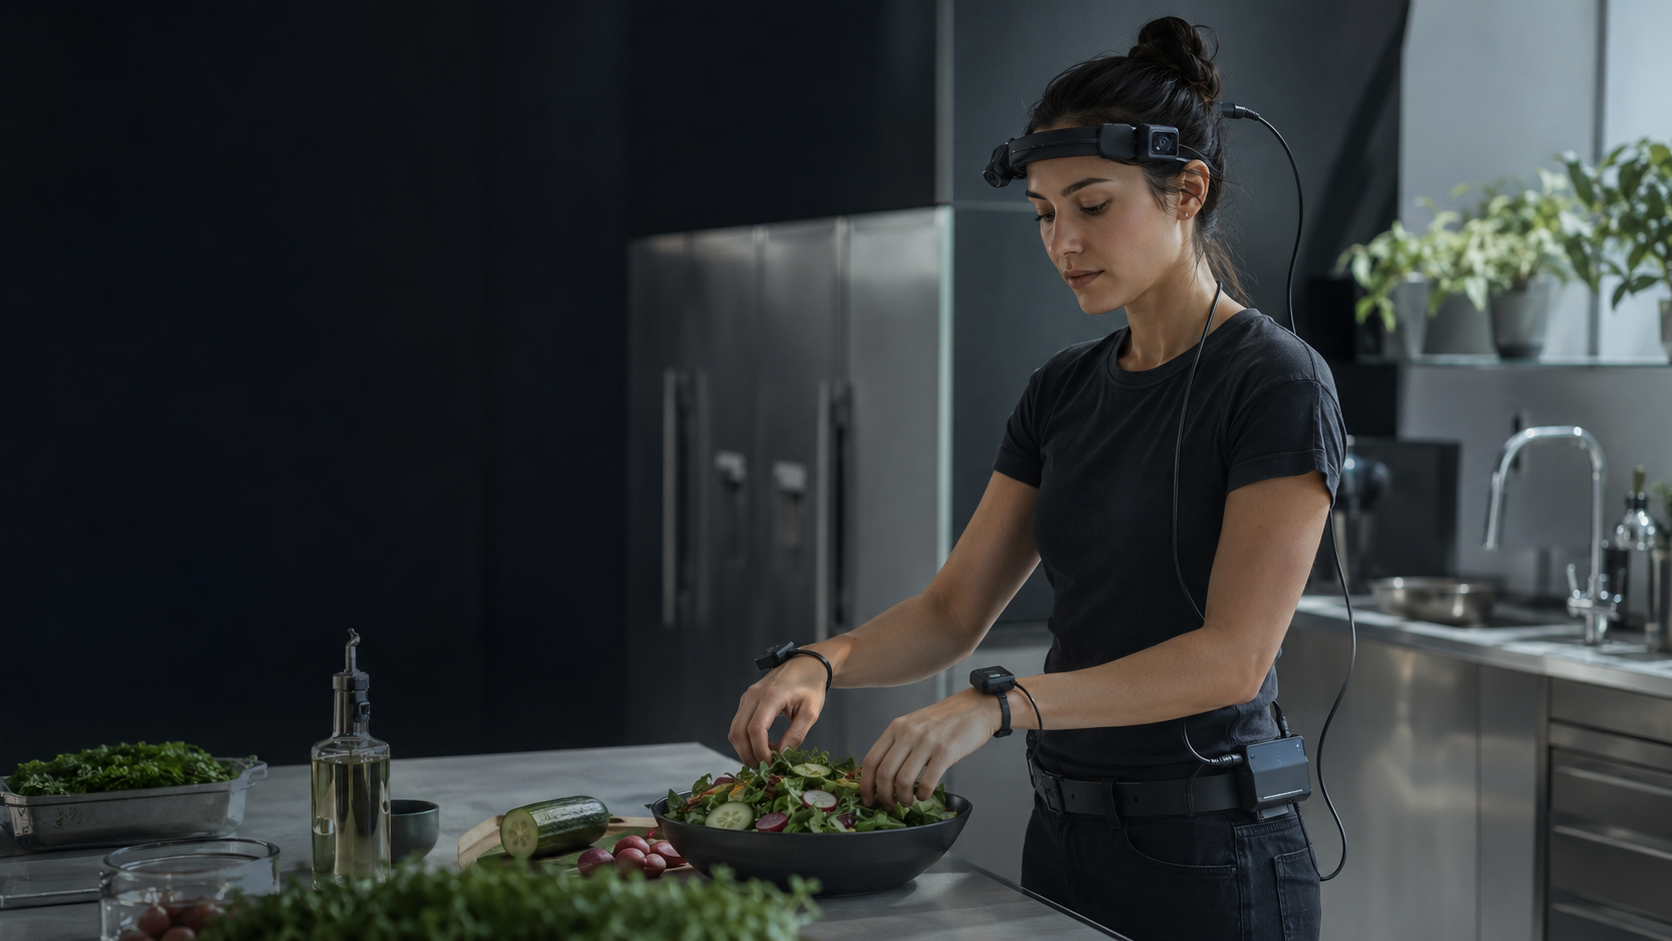
Empirical Intelligence builds the multimodal data infrastructure that turns real-world interaction into train-ready robot intelligence.
From Physical World to Training Data
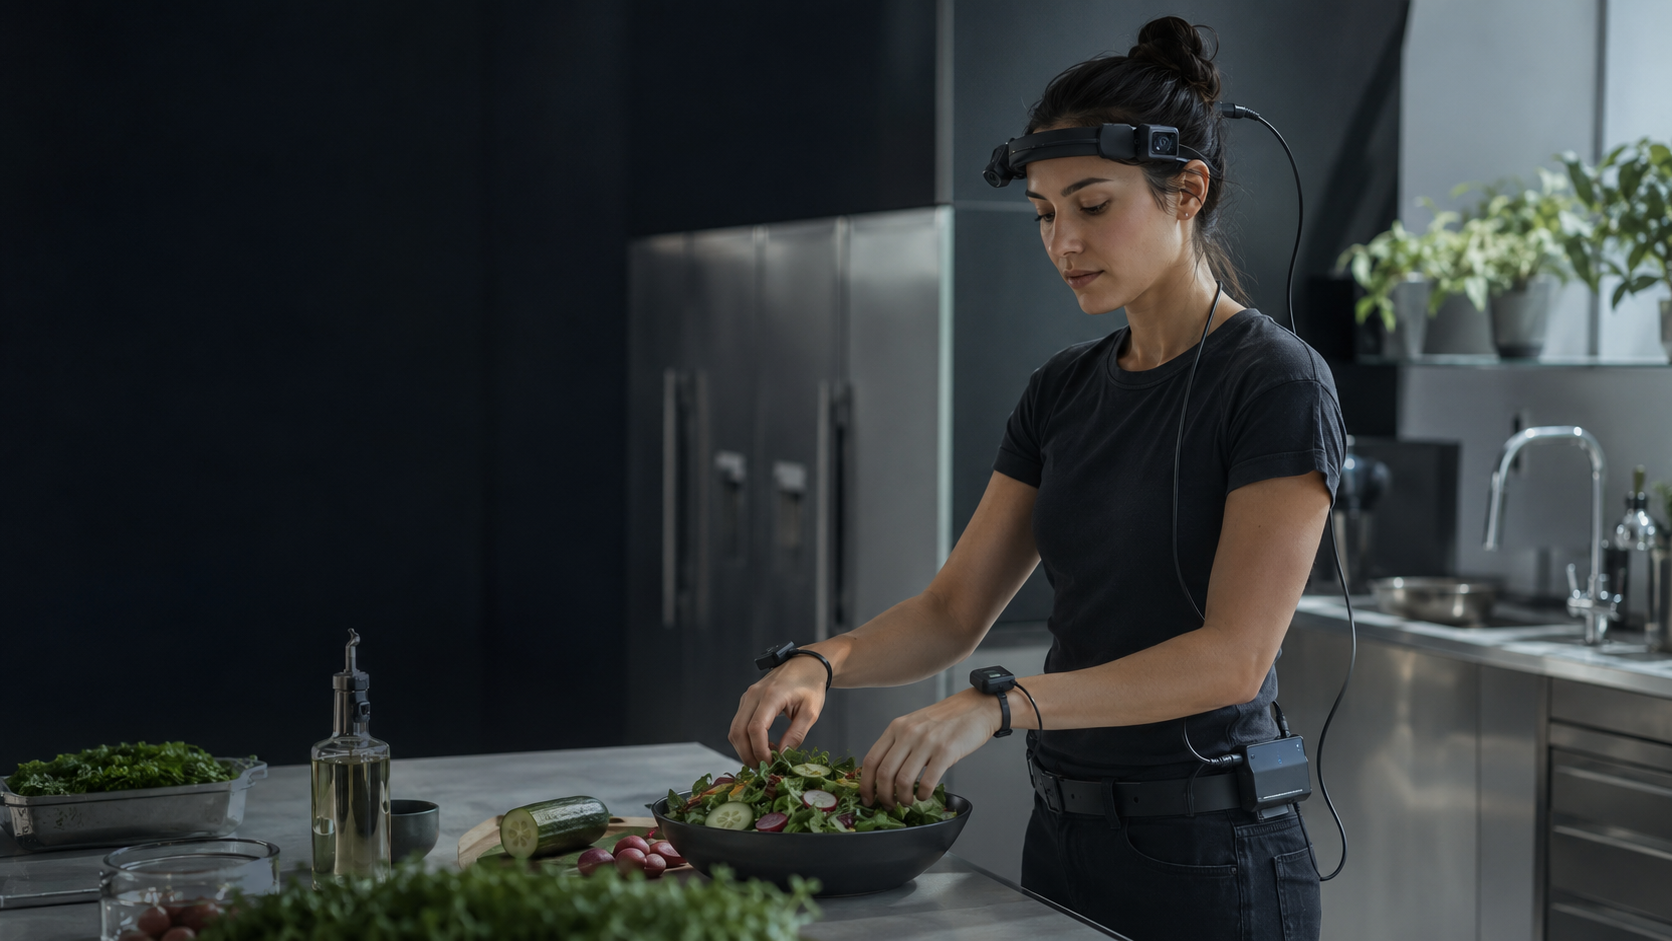
Perception
Ego captures human-scale vision, motion, audio, and context across real tasks.
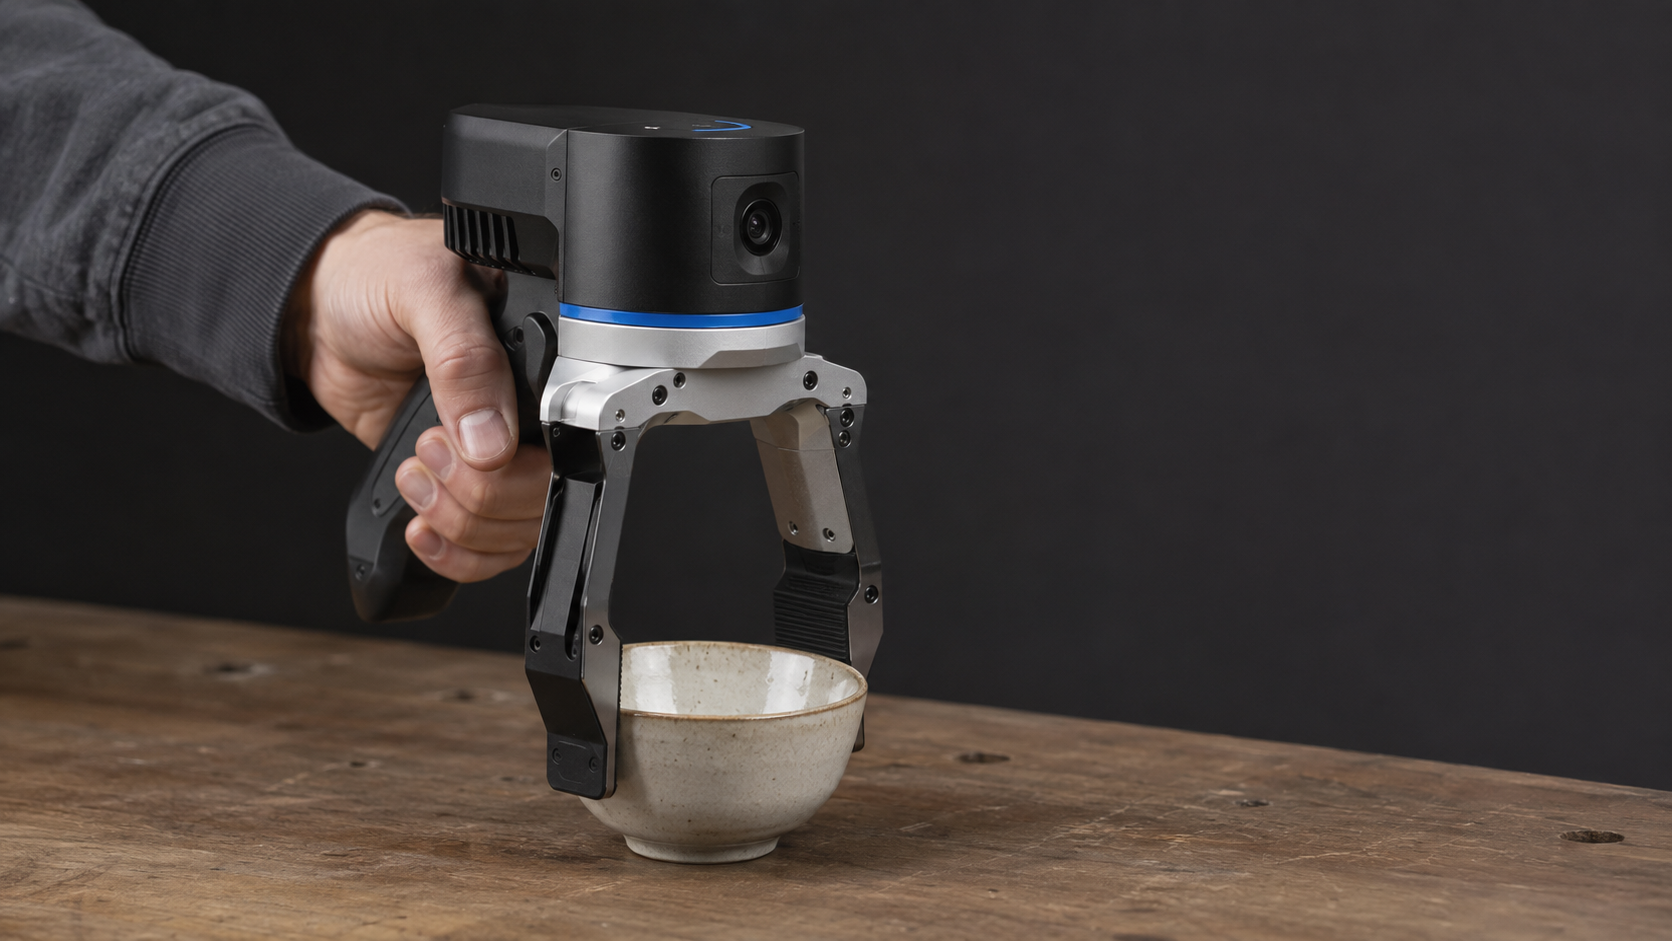
Position
UMI aligns wrist pose, end-effector motion, and interaction detail.
Action Data
Synchronize, calibrate, govern, and export episodes in LeRobot, RLDS, and HDF5.
Robot intelligence is empirical. Every physical interaction can become structured, traceable, reusable training data.
A Full-Stack Robot Data Infrastructure
Ego Data Capture
Ego Lite, Ego Pro, and Ego-9C capture multimodal human interaction at the fidelity each task requires.
UMI & Robot Real Data
Gripper-mounted sensing connects human demonstrations with robot end-effector state and action.
Data Governance Platform
Time synchronization, calibration, quality control, task segmentation, lineage, and dataset versioning.
Data Factory & Delivery
Scalable collection in real environments, standardized datasets, APIs, and private deployment.
Build With Us
Tell us the task, environment, robot embodiment, and data target. We will design the path from capture to deployment.
Data That Improves With Every Deployment
Models change. Embodiments change. The physical world keeps producing new edge cases. Our infrastructure is built for years of continuous collection, governance, and closed-loop improvement.
Shanghai · Suzhou / Taicang · Global Deployment